Intuition
Near an equilibrium a smooth system looks almost linear, just as a smooth curve looks almost straight close to a point. Replace the rates by their best linear approximations and what is left is a linear system in the small displacements from the equilibrium, whose matrix is the Jacobian: the partial derivatives of the rates. Everything the linear chapter learned about that matrix then describes the nonlinear system near that point — with one exception, the subject of the next lesson.
The Earth is round, but a street plan of one town is flat and perfectly good for getting about in it. The linearisation is the street plan of an equilibrium.
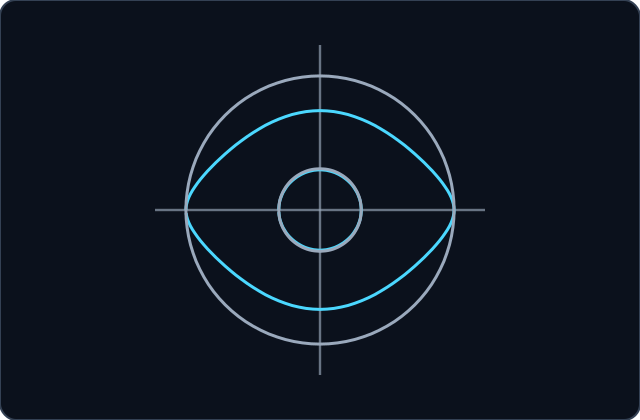
The pendulum's swings, solid, and those of its linearisation , , dashed circles, from the same starts. A small swing is almost exactly its circle; a large one is not, because is close to only near .
The Jacobian at an equilibrium
At an equilibrium put and . Since and vanish there, their first-order Taylor approximations give the linear system below, whose matrix is the Jacobian of evaluated at the equilibrium. The neglected terms are of second order in and , small compared with the linear ones close to the equilibrium.
Computing it
- Pendulum at : and give , the small swings .
Near an equilibrium the rates are linear plus smaller terms
Expand each rate about the equilibrium by Taylor’s theorem, to first order. The constant term vanishes because the point is an equilibrium, and the remainder is of second order in the displacement when the second derivatives are continuous. What is left is a linear system in the displacements, whose matrix is the Jacobian; near the equilibrium the remainders are small compared with it.
Proof steps
The first-order Taylor expansion, with a remainder R.
At an equilibrium the rate vanishes.
With continuous second derivatives the remainder is of second order.
The same for g; dropping R and S leaves the linear system with matrix J.
Applications
Practice
Partial Derivatives in a Square
Row one of the Jacobian differentiates f, row two differentiates g. Column one is the derivative in x, column two in y.
Try it
For and , the Jacobian at is below. Select the entry that is , the derivative of in .
Try it
What is the Jacobian of the pendulum , at ?
Try it
For , , what is at ?
Try it
A nonlinear system has one Jacobian matrix, the same at every equilibrium.
Try it
Why may the terms beyond the Jacobian be dropped near an equilibrium?
Try it
For , , what is at the equilibrium ?
Try it
Linearising the pendulum at gives the equation of small swings, .
Try it
For , , the Jacobian at is below. Select the entries that are partial derivatives of the first rate, .
Final checkpoint
Try it
What does the Jacobian at an equilibrium describe?
Try it
The Jacobian is built from first partial derivatives only.
Try it
For , , what is at ?
Completion
Lesson complete
Great work! You now know how to:
- compute the Jacobian at each equilibrium
- derive the linearisation from Taylor’s theorem
- read the linear system it gives
- say where the linearisation can be trusted